New preprint: hierarchical MPC–RL control for multi-timescale battery systems
How can a battery chase profit opportunities that last seconds without wearing itself out over the following months? 🔋
Our new preprint, Hierarchical Control via MPC-RL for Multi-Timescale Battery Systems, by Rasa Pourjam, Ehecatl Antonio del Río Chanona and Paulina Quintanilla, is now on arXiv. It is the full paper behind the work we presented at the IFAC World Congress in Busan.
The idea
Many systems have to make fast operational decisions while meeting slow, long-horizon targets. We separate the two with a hierarchy:
- a high-level model predictive control (MPC) layer optimises long-horizon setpoints on the slow timescale, where battery degradation plays out;
- a low-level reinforcement learning agent, trained in advance, tracks those setpoints in real time to make the most of short-term opportunities.
Using reinforcement learning at the fast level means the controller can learn nonlinear policies without linearising the model, and without solving a heavy optimisation problem at every step.
The result
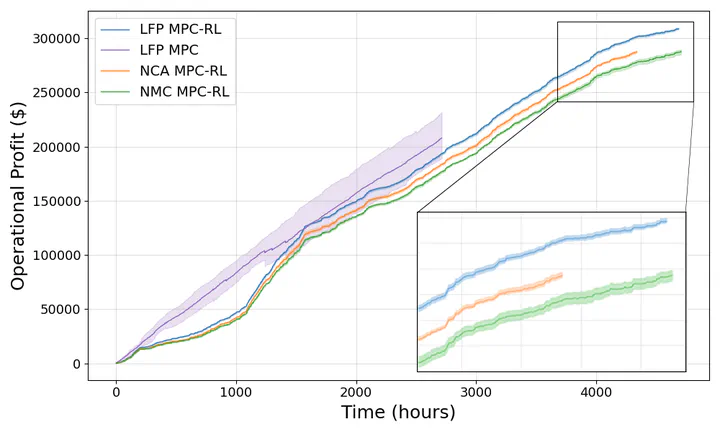
We applied the framework to a battery energy storage system operating in frequency regulation markets, where profit is made in seconds but degradation builds up over weeks to months. Compared with MPC baselines, the approach extended battery lifetime by 84% and increased operational profit by 34%.
Read more
- 📄 Preprint: arXiv:2610.03508
- 📚 Publication page
Congratulations to Rasa Pourjam, who led this work! 🎉

Dr Paulina Quintanilla
Assistant Professor in Process Systems Engineering
Assistant Professor in Process Systems Engineering at UCL, leading the LOOPS research group. Research interests include machine learning, optimisation and control for processes and physical systems.